
Thứ bảy, 26/09/2026 | 01:29


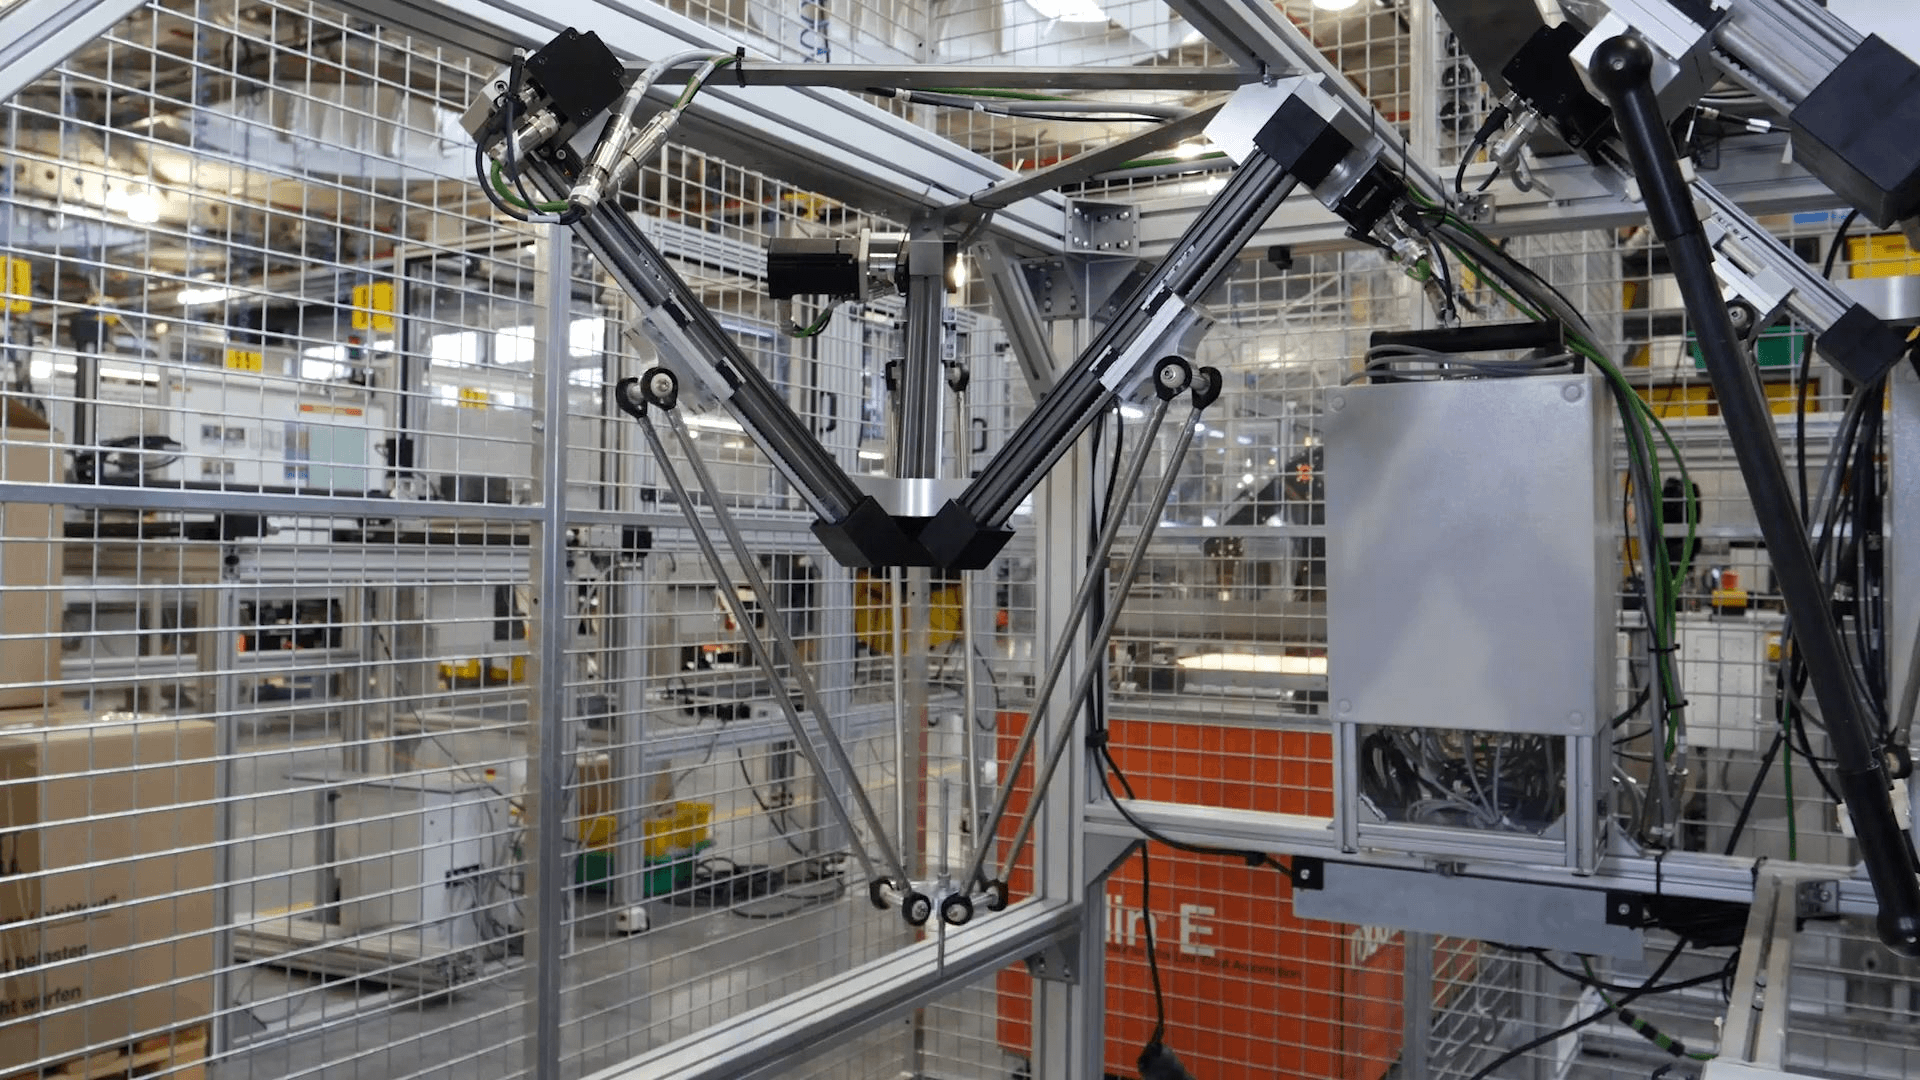
DESIGN OF THE ROBOT DELTA PARAMETER BASED ON THE ROBOT WORKSPACE Abstract: Delta robot is a parallel robot which can provide precise positions of the working head so it is widely used in industrial applications to pick-and-drop products in the production lines. The optimization of parameters of the robot to obtain the desired workspace is an important task. This paper provides a method to determine the robot parameters based on a given robot workspace. The algorithm used to calculate the forward kinematics and the constraints between the basic dimensions of the robot arms are proposed. The optimal algorithm used to limit the parameter domain to the dimensions of the arms of the robot is also proposed in the paper. Keywords: Robot kinematics, Delta robots, robot workspace, simulation |
Thay mặt Chính phủ, Phó Thủ tướng Hồ Quốc Dũng ký Nghị quyết số 282/NQ-CP ngày 22/9/2026 ban hành Kế hoạch hành động của Chính phủ thực hiện Kết luận số 51-KL/TW ngày 17/6/2026 của Bộ Chính trị về đẩy mạnh công tác sở hữu trí tuệ phục vụ phát triển kinh tế - xã hội trong tình hình mới.
24/09/2026
Thay mặt Chính phủ, Phó Thủ tướng Hồ Quốc Dũng ký Nghị quyết số 282/NQ-CP ngày 22/9/2026 ban hành Kế hoạch hành động của Chính phủ thực hiện Kết luận số 51-KL/TW ngày 17/6/2026 của Bộ Chính trị về đẩy mạnh công tác sở hữu trí tuệ phục vụ phát triển kinh tế - xã hội trong tình hình mới.
24/09/2026